Course delivery status
This page is the delivery ledger for the 19 K/L lesson IDs. It separates the reading or concept page from usable numerical evidence and from teaching media. A published page is not automatically a runnable experiment or a video lecture. The shared rules are in the lesson delivery policy.
Evidence and media matrix
Available means that the linked artifact is checked in and usable for the
named question. Planned means the question is useful but its run or render is
not complete. Not needed means a static derivation or compact figure carries
the question more clearly; the reason is stated in the row.
| ID | Page class | Usable evidence | Video status and named question |
|---|---|---|---|
| K0 | Concept + cited lab | L0 mismatch report and replayed mismatch clip | Available · 1: l0-mismatch.mp4, reused for “what does a bad model look like?” |
| K1 | Reading | Signal and parameter explanation on page | Not needed: the boundary table and exercise are shorter and clearer as static text |
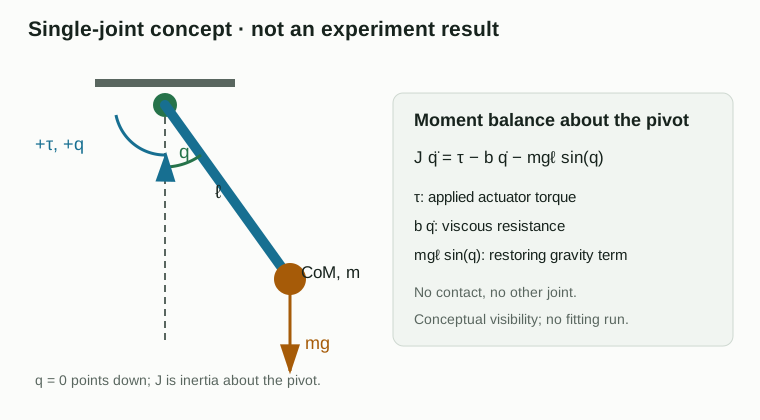
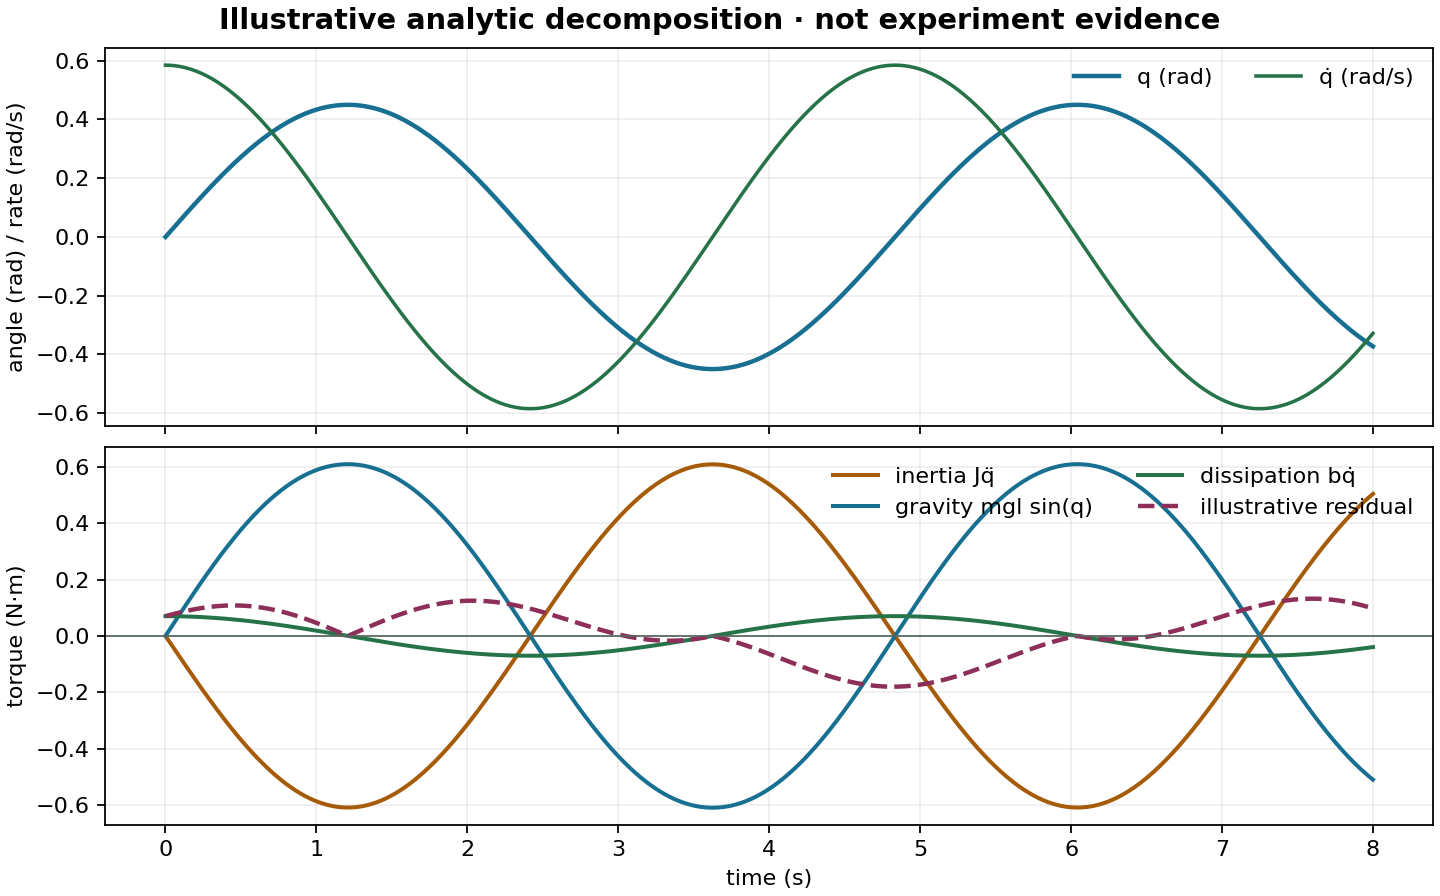
| K2 | Concept | Labelled pendulum diagram and analytic decomposition; explicitly illustrative | Not needed: a static derivation and figure answer the units/force-balance exercise; no experiment evidence is implied |
| K3 | Concept + cited L1 | L1 friction report and L1 boundary evidence | Available · 3 reused: l1-boundary.mp4, l1-phase.mp4, l1-friction.mp4 for command delay and resisting torque |
| K4 | Concept + L0-E evidence | L0-E report and sensitivity/coverage figures | Available · 1 reused: l0-excitation.mp4 for the excitation comparison |
| K5 | Concept + L0 evidence | L0 report, fit path and multi-start metrics | Available · 1 reused: l0-fit-walk.mp4 for how an optimizer path changes the model |
| K6 | Concept + held-out evidence | L0 report, fit/held-out split and residuals | Available · 1 reused: l0-heldout.mp4 for a prediction on a withheld motion |
| K7 | Concept + cited friction evidence | L1 friction report, with effective-parameter limits | Not needed: the report figure and comparison table carry the compensation question; no extra clip is required |
| K8 | Concept | Control/transfer protocol and answer guide on page | Not needed: the bounded protocol is a static design decision; downstream robot evidence is planned with L4 |
| L0 | Runnable | L0 fixed report, metrics and local runner | Available · 5: mismatch, fit lands, fit walk, robust starts, held-out |
| L0-E | Runnable | L0-E frozen report, sensitivity/coverage/loss/multistart/held-out outputs | Available · 1: l0-excitation.mp4 for weak excitation and comparison |
| L1 | Runnable | L1 report plus friction report | Available · 4: boundary, phase, held-out, friction |
| L1-O | Design draft | Contract and planned observation-noise comparison on page; no checked run | Planned: observation noise has a named residual question, but no rendered clip or report yet |
| L1-S | Design draft | Contract and planned saturation comparison on page; no checked run | Planned: saturation would benefit from a clip once its local run exists |
| L2 | Design draft | Coupled-leg contract; simulator/report pending | Planned: coupling and parameter compensation need a real leg run before a clip is made |
| L3 | Design draft | Contact contract; simulator/report pending | Planned: contact onset and residuals need a real run |
| L4 | Design draft | Whole-robot/control-comparison contract; report pending | Planned: component/global route and bounded controller comparison need checked evidence |
| L5 | Design draft | Parameter-sharing contract; report pending | Planned: comparing independent and shared parameters needs the actual scaling run before a clip can be made |
| L6 | Design draft | Structural-mismatch and cross-engine contract; reports pending | Planned: two mismatch cases require actual backend runs before media can be scoped |
The ten independent current clips are short, silent teaching aids; subtitles and written explanations carry the language-specific narrative. Reused clips are counted in each lesson only when their question and boundary are stated. L1-O, L1-S, and L2–L6 remain design drafts; independent learner acceptance for L0/L1 and the full course is still pending.
Current delivered path
K0, K1, L0 and L1 are readable today. L0 and L1 have reproducible local CPU runners and checked reports; L1 includes the isolated friction extension. L0-E is now a runnable CPU evidence package. K2 is a concept lesson with a derivation and analytic teaching figure, explicitly separate from experiment evidence. K3–K8 cite the evidence that answers their questions or state why a clip is not needed. The remaining L pages are contracts awaiting their numerical paths.
The website provides paired English and Chinese pages. Marimo apps remain local adapters; a browser/WASM surface is optional and is never inferred from page publication. Independent learner acceptance still requires an actual reader to identify the initial mismatch, explain held-out performance, change one setting, and state the assumptions.